Real-Time Evant-Camera Odometry
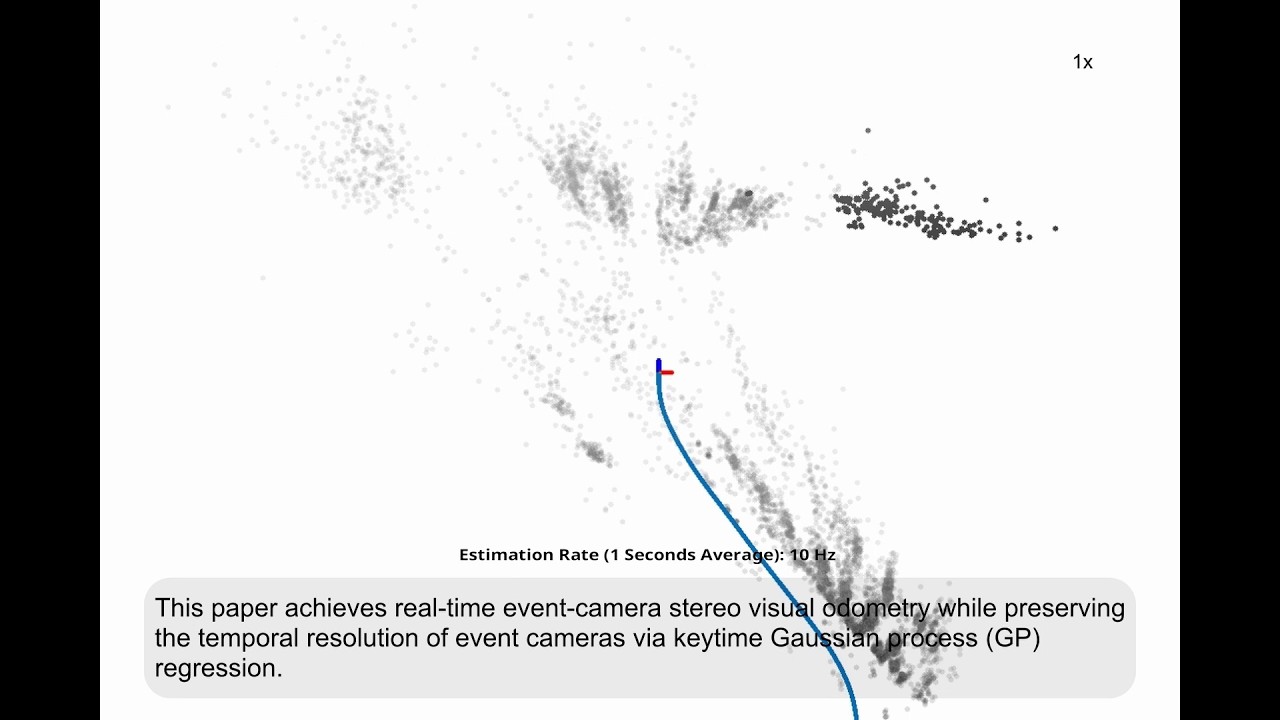
Nikan is researching event-camera odometry and has exciting new results with a stereo pipeline that runs in real time. The pipeline maintains the asynchronous microsecond temporal resolution of event cameras by using a continuous-time Gaussian process estimator. The work is currently under review, but you can read the open access paper on arXiv and watch the video on YouTube!